diasAiMaster/unitree-go2-velocity-flat
By diasAiMaster · ↓ 0 · ♥ 1 · Updated 2026-02-07
What's in this repo
This page lists the files in diasAiMaster/unitree-go2-velocity-flat, including policy.onnx.
- 1 ONNX models (.onnx files)
- 26 files, including 11 .log, 6 .pt, 2 .0, 2 .yaml, 1 .md, 1 .diff
- Last updated 2026-02-07
ONNX files
| File | Size | Download |
|---|---|---|
| policy.onnx | — | Download |
How to use
These ONNX files can be loaded with ONNX Runtime. To inspect a model graph, upload the file to the Netron viewer. Download links point to the original files on Hugging Face.
README
Unitree Go2 — Velocity Flat (PPO)
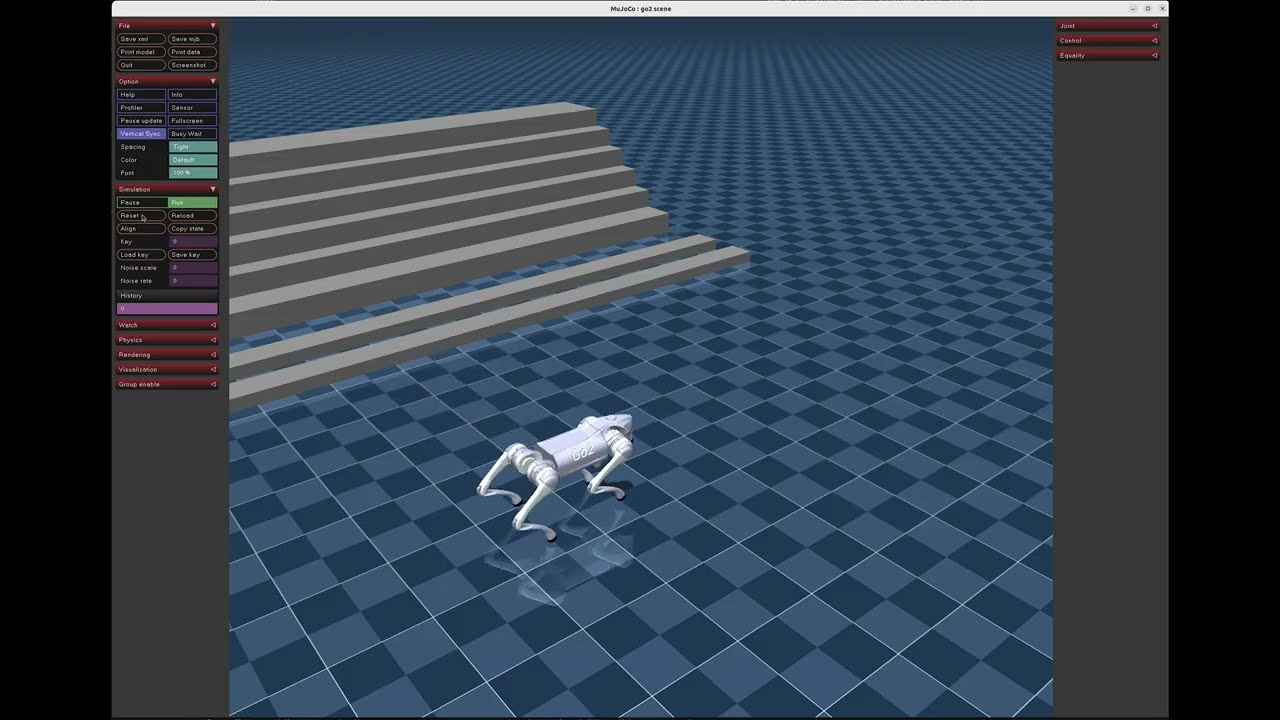
RL locomotion policy for the Unitree Go2 quadruped robot, trained on flat terrain using PPO.
Demo
Training
- Framework: unitree_rl_mjlab (MuJoCo Warp)
- Task:
Mjlab-Velocity-Flat-Unitree-Go2 - Algorithm: PPO (RSL-RL)
- Hardware: 10× NVIDIA RTX A4000, 56 CPU cores
- Environments: 8192 parallel
- Training time: ~18 minutes (506 iterations)
Results
| Metric | Value |
|---|---|
| Mean reward | 52.9 |
| Mean episode length | 1000 (max, no falls) |
| Steps/sec | 628K-738K |
Files
| File | Description |
|---|---|
policy.onnx + policy.onnx.data |
ONNX model for deployment (go2_ctrl) |
model_500.pt |
Final PyTorch checkpoint (best for fine-tuning) |
model_0.pt ... model_400.pt |
Intermediate checkpoints every 100 steps |
params/env.yaml |
Environment configuration |
params/agent.yaml |
Agent/PPO configuration |
events.out.tfevents.* |
TensorBoard training logs |
Usage
Deploy in MuJoCo simulator
# Copy ONNX model
cp policy.onnx policy.onnx.data \
  unitree_rl_mjlab/deploy/robots/go2/config/policy/velocity/v0/exported/

# Run simulator + controller
cd unitree_mujoco/simulate/build && ./unitree_mujoco
cd unitree_rl_mjlab/deploy/robots/go2/build && ./go2_ctrl --network=lo
Fine-tune on rough terrain
# Place model_500.pt in logs/rsl_rl/go2_velocity/<run_name>/
python scripts/train.py Mjlab-Velocity-Rough-Unitree-Go2 \
  --agent.resume=True \
  --agent.load-run="<run_name>" \
  --agent.load-checkpoint="model_500.pt" \
  --agent.algorithm.learning-rate=1e-4
Known Issues
The upstream unitree_rl_mjlab has bugs that crash multi-GPU training on rough terrain — see Issue #9 and PR #8.
Model info
Created: 2026-02-06
Updated: 2026-02-07
View on Hugging FaceFiles (26)
Related models
More from diasAiMaster
No other models by this author.